Farzad Nadiri - Applied Scientist
Hi there 👋 I am Farzad,
I’m an applied scientist working where perception meets language models, with a PhD research track in autonomous driving at Simon Fraser University and more than a decade of shipping production software.
On the perception side, I build bird’s-eye-view camera perception, IMU and camera sensor fusion for localization, and vision-based lateral control, validated both in CARLA and on physical robots. On the language side, I built DriveMCP, an agentic multimodal driver-assistance system on the Model Context Protocol with retrieval-grounded reasoning and a guardrail that decides when the system may act versus only advise, and a speech and LLM transcription system deployed in BC’s court system.
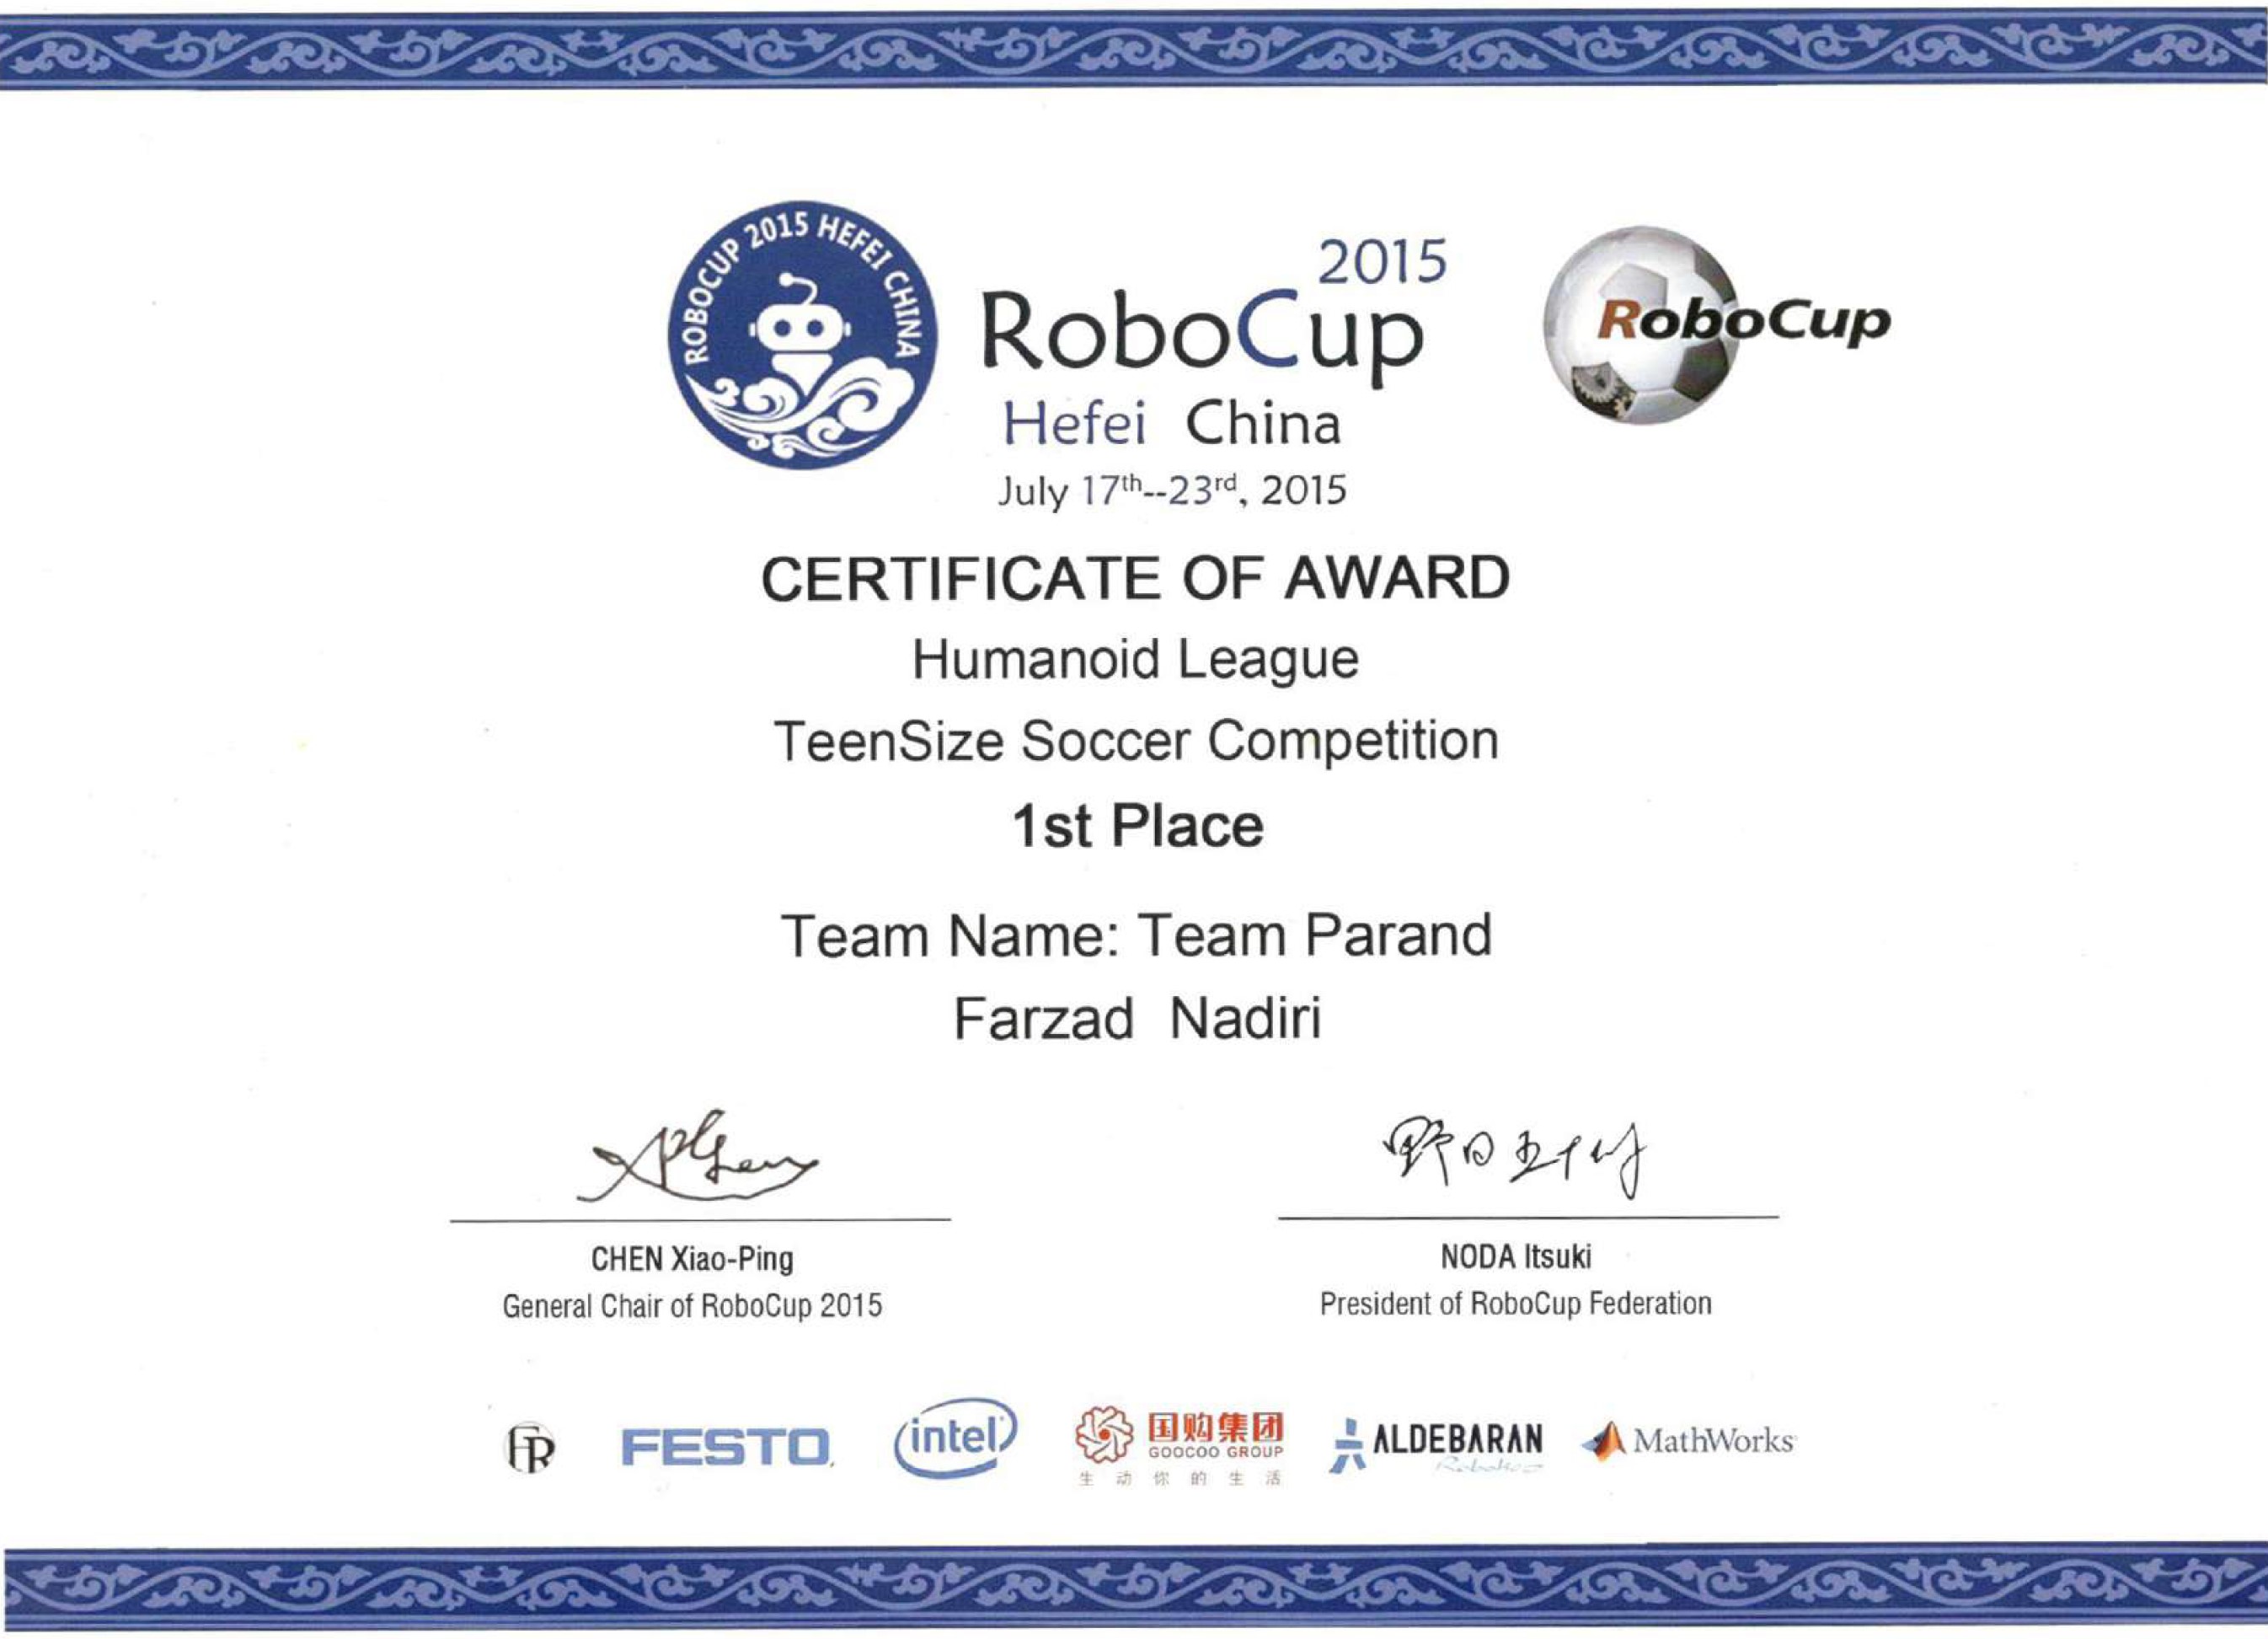
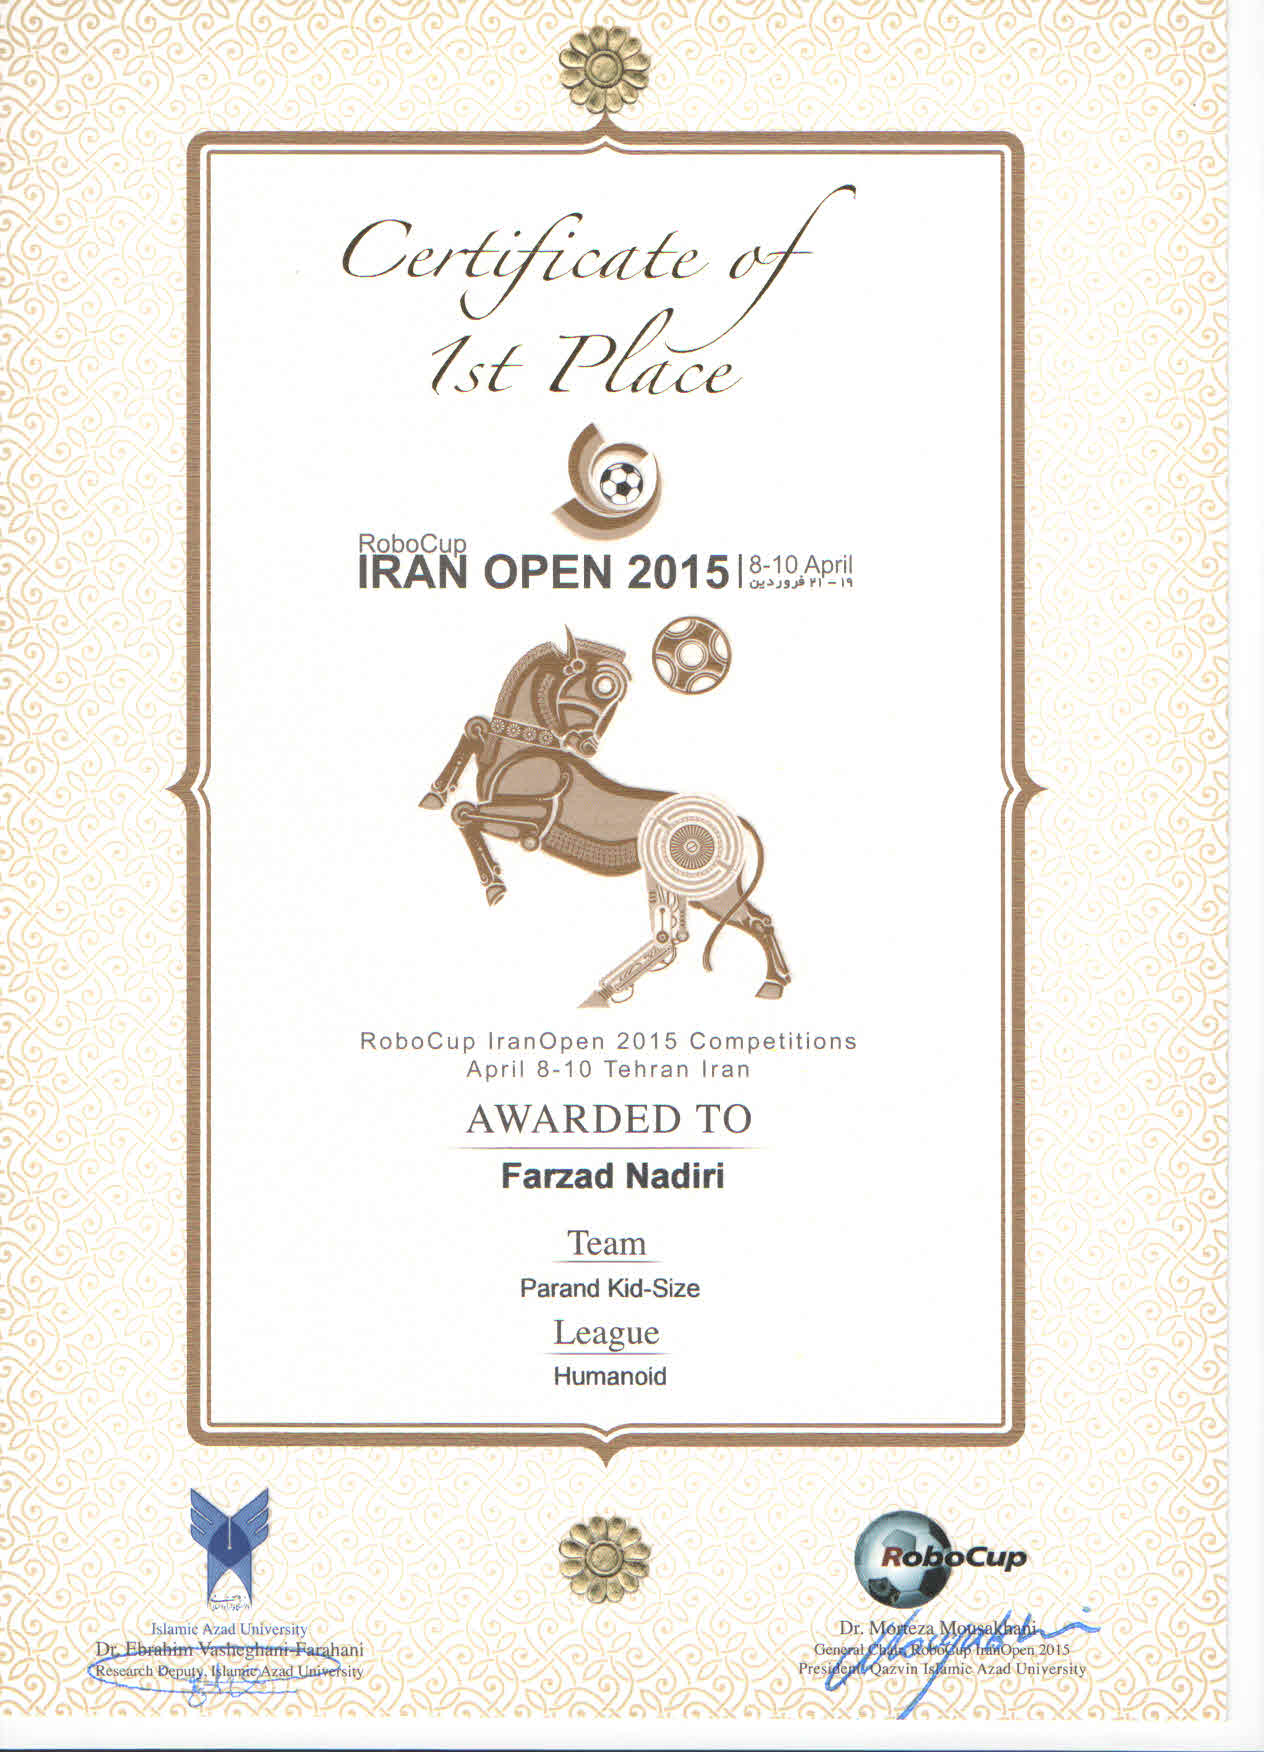
I like turning research into systems that actually run. At work I architect large-scale ML inference pipelines on AWS SageMaker, and earlier in my career I won the RoboCup 2015 TeenSize humanoid world championship with Team Parand. I work end to end, from data and modeling to deployment and monitoring, and I like measuring a system against a real baseline before trusting it.
Let us connect and build something impactful together!
Current roles
- Senior Software and ML Engineer, Quartech
- PhD Student, Mechatronic Systems Engineering, AI and Robotics, Simon Fraser University
- Research Assistant, Autonomous and Intelligent Systems Lab, SFU
Focus areas
- Camera and multi sensor perception for autonomous driving and robotics
- Sensor fusion, localization, and control under real world uncertainty
- Vision language models and agentic architectures for driver assistance
- Design and deployment of cloud based, production grade ML services
Core skills
- Perception and sensor fusion: 2D and 3D detection and tracking, semantic scene understanding, camera calibration, homography and bird’s eye view transforms, IMU and camera fusion, 3D point cloud localization, lane and obstacle perception, multi rate sensor synchronization, CARLA, CAN and OBD-II with DBC decoding
- Deep learning: PyTorch, CNNs, Vision Transformers, temporal transformers, cross attention multimodal fusion, vision foundation models, vision language models, LLMs and RAG, subject wise cross validation
- Production ML and infrastructure: AWS SageMaker for training, batch inference and endpoints, MLflow tracking and model registry, S3, large scale image and sensor log pipelines, dataset curation, automated label QC and scoring, Docker, GitHub Actions CI/CD, CUDA and GPU serving, vLLM, Azure ML, OpenShift AI
- Languages and tooling: Python, C#, C, C++, TypeScript, Java, SQL, NumPy, Pandas, OpenCV, Hugging Face Transformers, python-can, cantools, pytest, ruff and mypy, Git
Work experience
-
Senior Software and ML Engineer, Quartech, Oct 2023 to Present, Vancouver, Canada
Digital pathology quality control AI, Provincial Health Services Authority
-
Led the AI solution for automated quality control of whole-slide pathology images for PHSA, flagging low-quality scans before they reach pathologists: gigapixel tiling and embedding extraction with a frozen pathology foundation model on AWS SageMaker.
-
Built a class-weighted logistic-regression baseline on pooled slide embeddings, using a threshold sweep to set the operating point, then an attention-based multiple instance learning (MIL) model over up to 1,500 tiles per slide so small, localized defects are not diluted by averaging; on a held-out test set of slides, MIL reached 0.97 ROC-AUC and 93% accuracy, catching 90% of failing slides at 88% precision.
-
Turned MIL attention, weighted by each slide’s failure probability, into smoothed heatmap overlays so pathologists can see which regions drove a FAIL decision.
-
Stood up MLflow experiment tracking and a model registry around SageMaker training jobs so runs, datasets and artifacts stayed reproducible, and models were promoted through a versioned registry.
Court session transcription AI, BC Court Systems
- Fine tuned Whisper for courtroom audio covering legal terminology, overlapping speakers, and far field recording, and shipped it as a privacy preserving, self hosted GPU and CUDA deployment inside the ministry environment
- Designed a case aware context refinement layer in which an LLM post processes the transcript against party names, statutes, and matter records, correcting proper nouns and citations that acoustic decoding alone gets wrong
Early Childhood Education Registry, BC Ministry of Education and Childcare
- Led backend development of a province wide certification platform, integrating with government systems and shipping through GitHub Actions CI/CD into containerized OpenShift deployments, with accessibility and security compliance
-
-
Senior Software Engineer, Pacific Blue Cross, Jan 2023 to Jul 2023, Vancouver, Canada
-
Raised throughput of a data mapping platform serving one million users by about 25 percent through service oriented architectural refactoring and automated test coverage, and authored migration tooling across legacy databases
-
Enhanced scalability and reliability by improving monitoring, refining data access patterns, and collaborating with cross functional teams on incident response and performance tuning
-
Research experience
-
Research Assistant, Autonomous and Intelligent Systems Lab, SFU, May 2024 to Present, Vancouver, Canada
Supervisor, Professor Ahmad B. Rad, link- Built DriveMCP, an agentic driver assistance architecture that decomposes a monolithic vision language driving assistant into specialized experts exposed as Model Context Protocol servers, covering traffic rule retrieval, weather and traction reasoning, and CAN and OBD vehicle health, coordinated by a stateful orchestration graph at sub second advisory latency.
-
Research Assistant, Autonomous Robots Lab, Team Parand, Jan 2011 to May 2016, Tehran, Iran
Kid Size (50 cm) and Teen Size (100 cm) 20 DOF humanoid robots, built from scratch- Designed and implemented the vision pipeline for object detection and tracking on humanoid robots, including color segmentation, feature extraction, and object classification
- Developed the soccer behavior layer with field localization, obstacle avoidance, and team tactics, connecting perception to decision making and motion control
- Implemented multi robot UDP communication for cooperation and coordination between agents, including message formats and synchronization strategies
- Built and maintained multithreaded modules, such as the omnidirectional bipedal walk engine, I and O, motion designer, and balance control components
Selected projects and code
-
MCP-CAN, vehicle telemetry over MCP
Open source Model Context Protocol server for live CAN and OBD-II decoding with cantools, including a virtual CAN backend and a multi ECU simulator so it runs with no hardware attached, Code -
DriverStateNet, multimodal driver impairment classification
Four class driver state classifier over the Toyota Research Institute Impaired Driving Dataset, fusing gaze, vehicle dynamics, and video with a temporal transformer and cross attention fusion, synchronized to 10 Hz with explicit missingness encoding and evaluated by UAR under subject wise folds. Manuscript in preparation, Code -
Look down lane perception and lateral control Homography-based bird’s-eye-view lane perception and lateral control for autonomous vehicles using a dual-camera look-down configuration, evaluated in CARLA across curved, uphill, downhill, and narrow-road scenarios., Paper, Code1, Code2
-
IMU and camera fusion for localization
Sensor fusion method that compensates perspective distortion under body tilt to improve position estimation in landmark sparse environments, validated on physical humanoid hardware, Paper, Code -
Modular humanoid soccer software framework
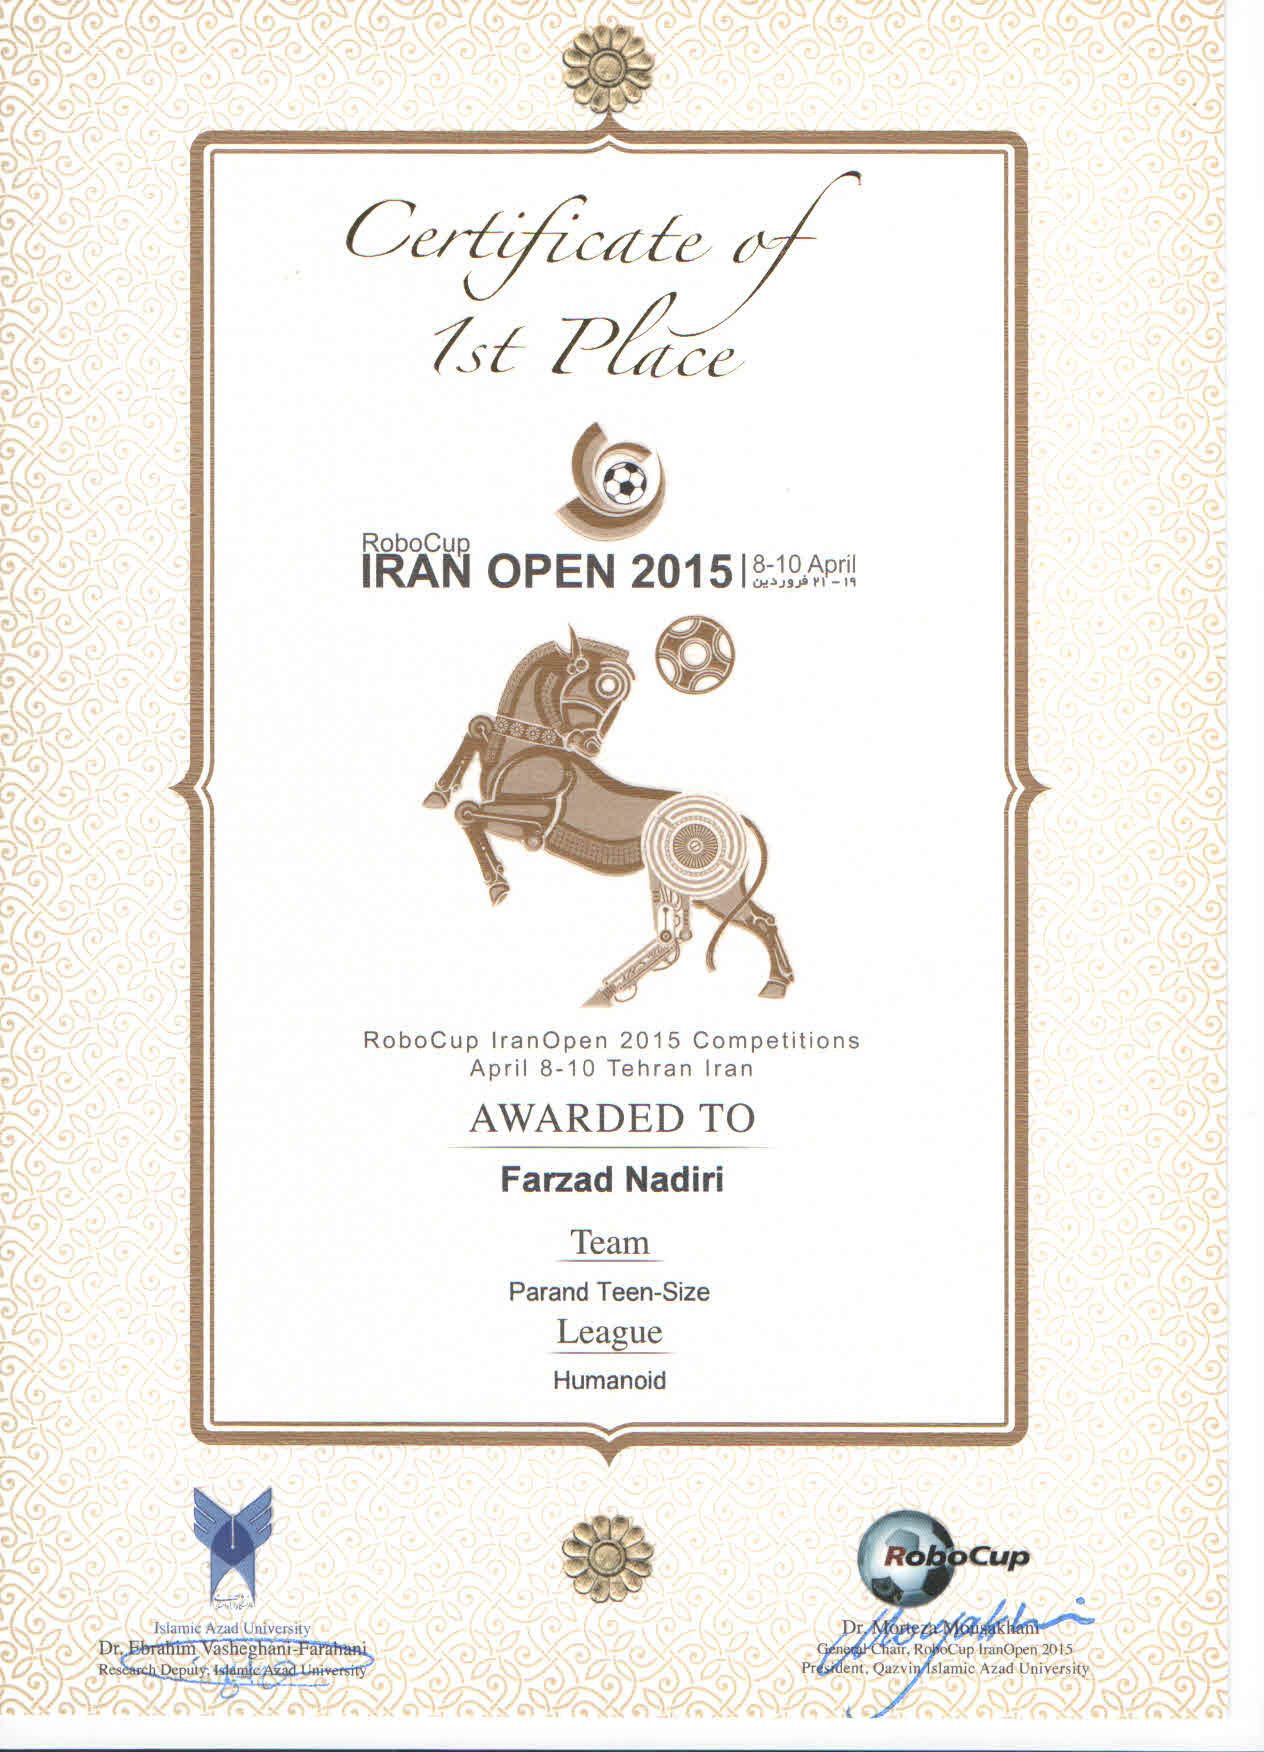
Modular software stack for humanoid soccer robots covering vision, behavior, localization, and motion, used on Teen Size and Kid Size platforms in RoboCup and IranOpen competitions, Report, Code
Education
-
PhD, Mechatronic Systems Engineering, AI and Robotics, Simon Fraser University, May 2024 to Present, Vancouver, Canada
Research, perception and control for autonomous systems, sensor fusion and localization, agentic architectures for driver assistance, simulation to real validation using CARLA and physical platforms -
M.Sc., Computer Science, AI and Robotics, Science and Research University, 2020, Tehran, Iran
Thesis, A Fusion of Inertial Measurement Unit Data and Bird’s Eye View Perspectives, focused on improving localization accuracy through sensor fusion, Best Master Thesis Award -
B.Eng., Information Technology, Azad University, Parand Branch, 2014, Tehran, Iran
Final project, Modular Software Framework for Humanoid Soccer Robots, including perception, behavior, localization, and motion modules
Honors and awards
- Special Graduate Dean’s Entrance Scholarship, Simon Fraser University, 44k CAD
- Supported by the National Elites Foundation of Iran, 2020 to 2022
- Best Master Thesis Award, Science and Research University, 2020
- Best Student Research Award, four consecutive years, Research Week, 2011 to 2015, Tehran, Iran
-
Referee Committee Member, ICT Challenge national competitions, Sharif University, Jul 2020, link
-
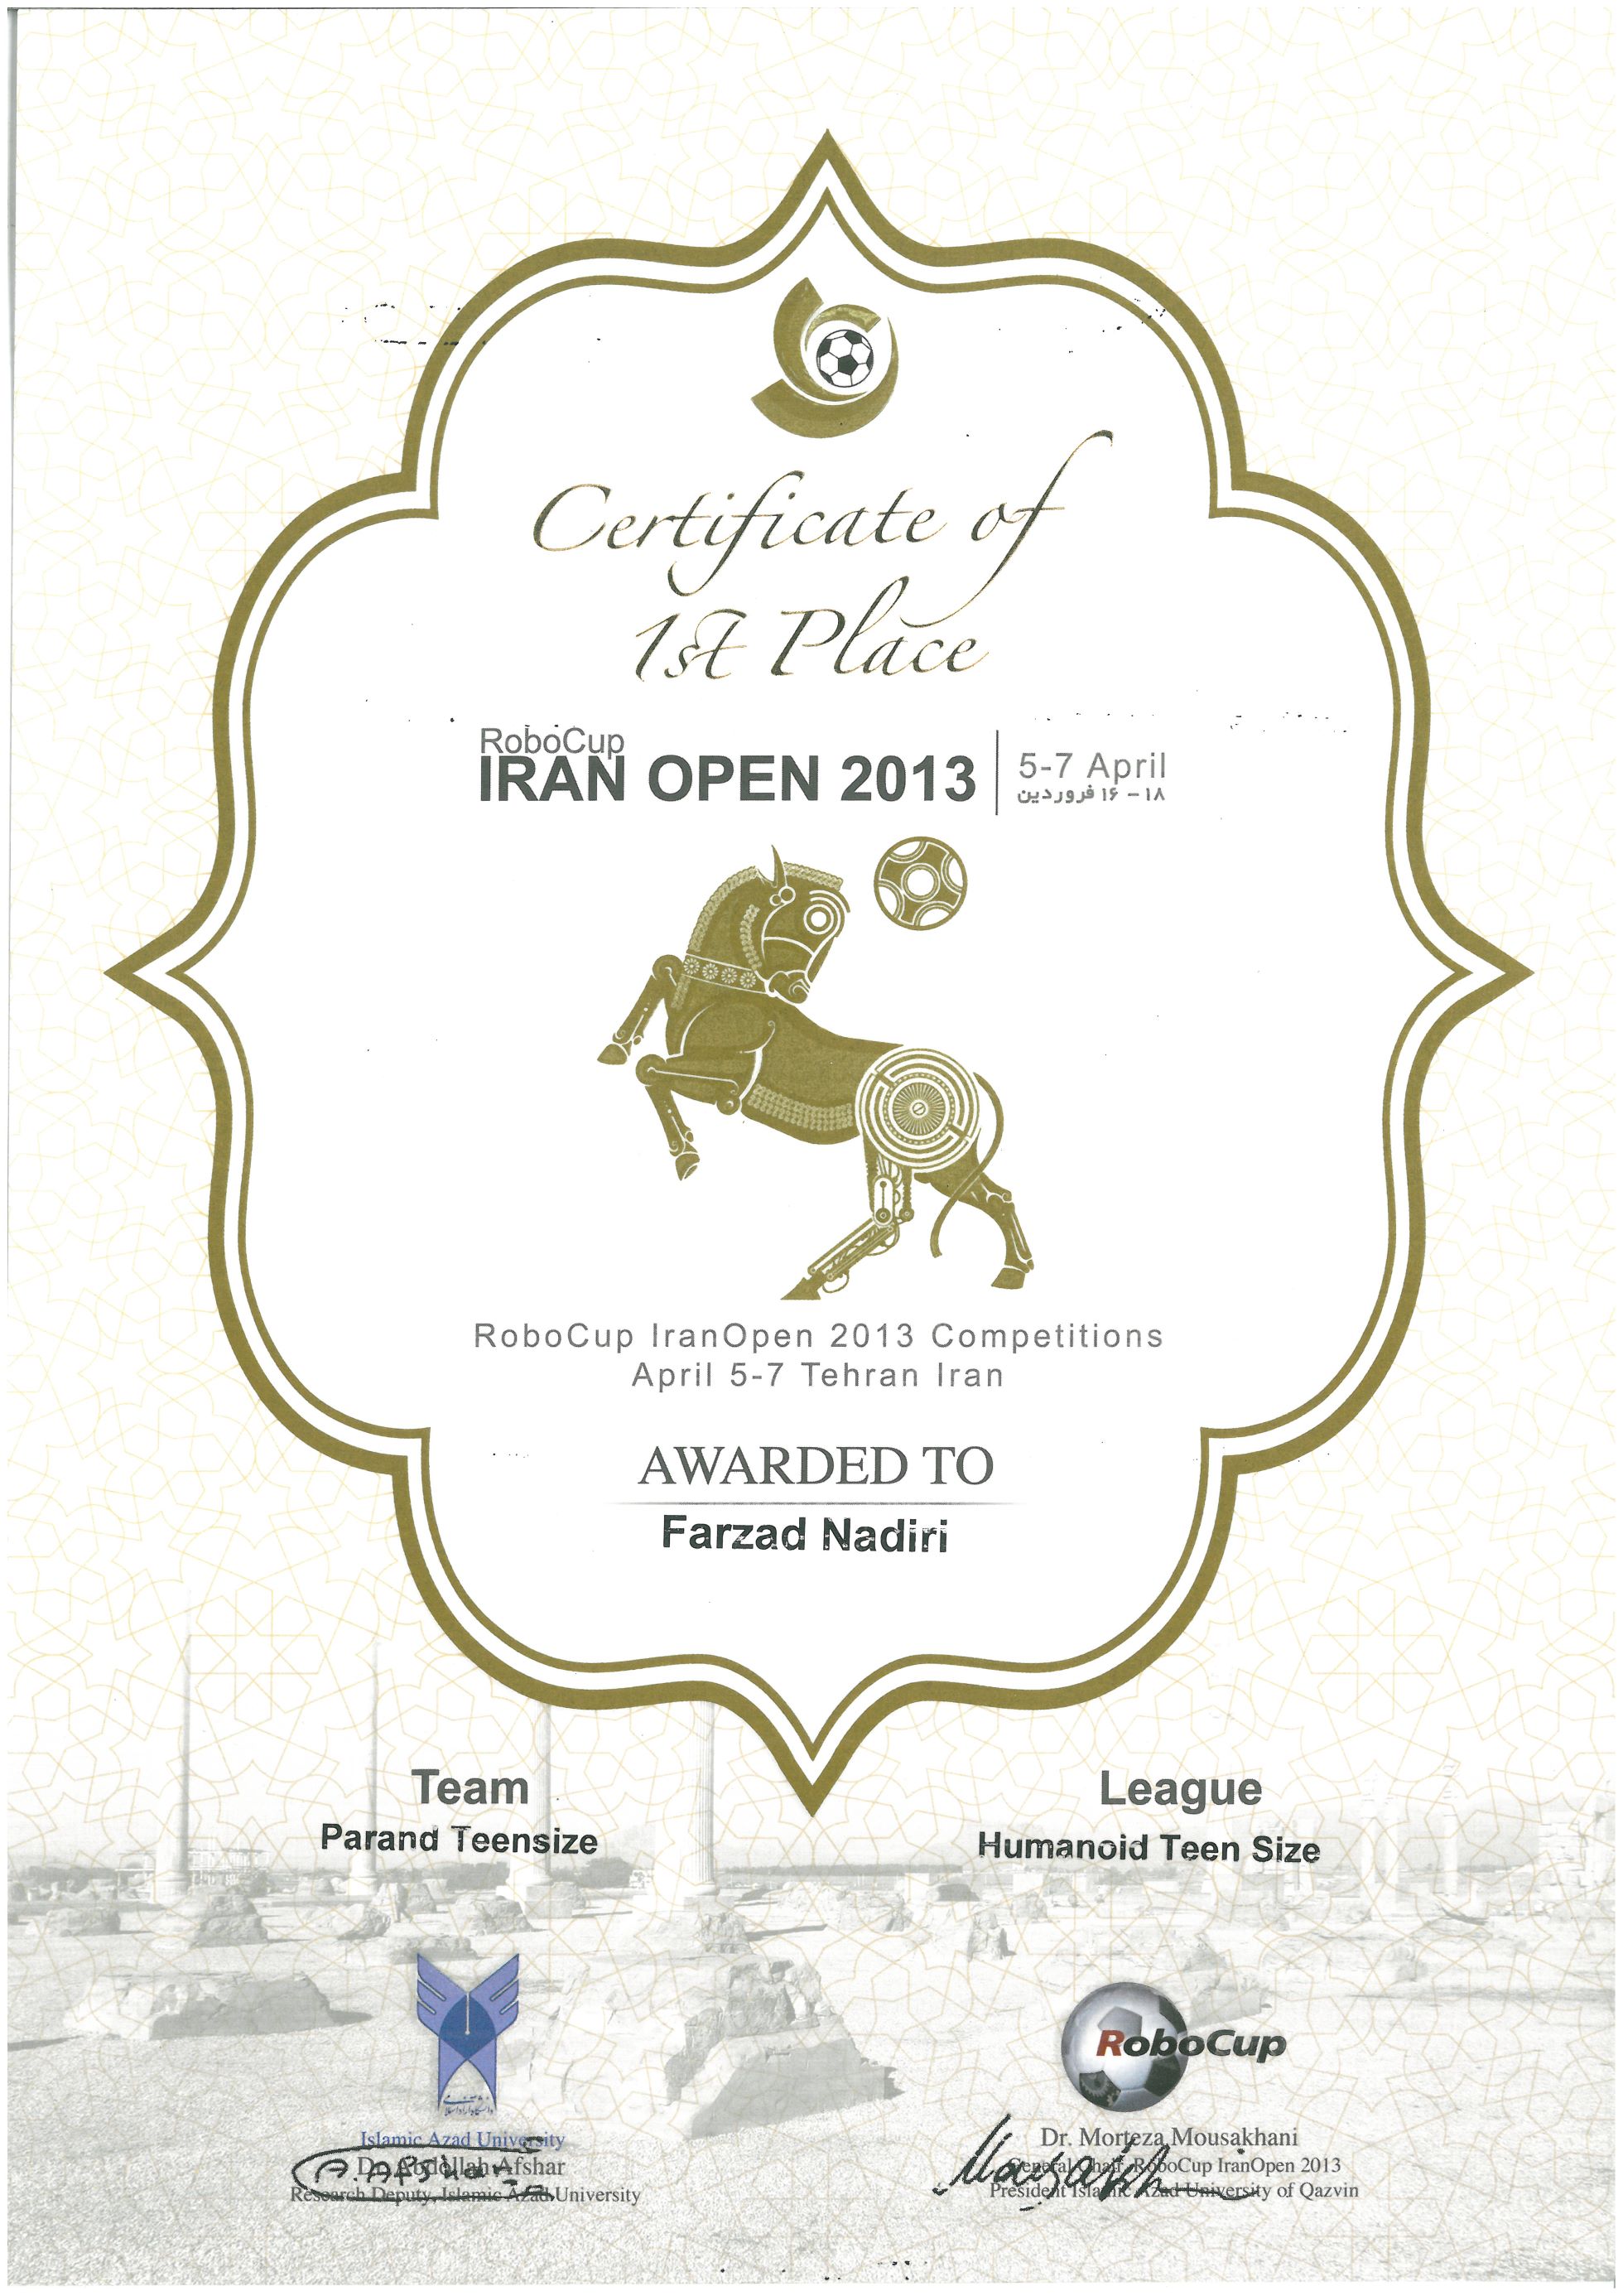
RoboCup, Teen Size Humanoid
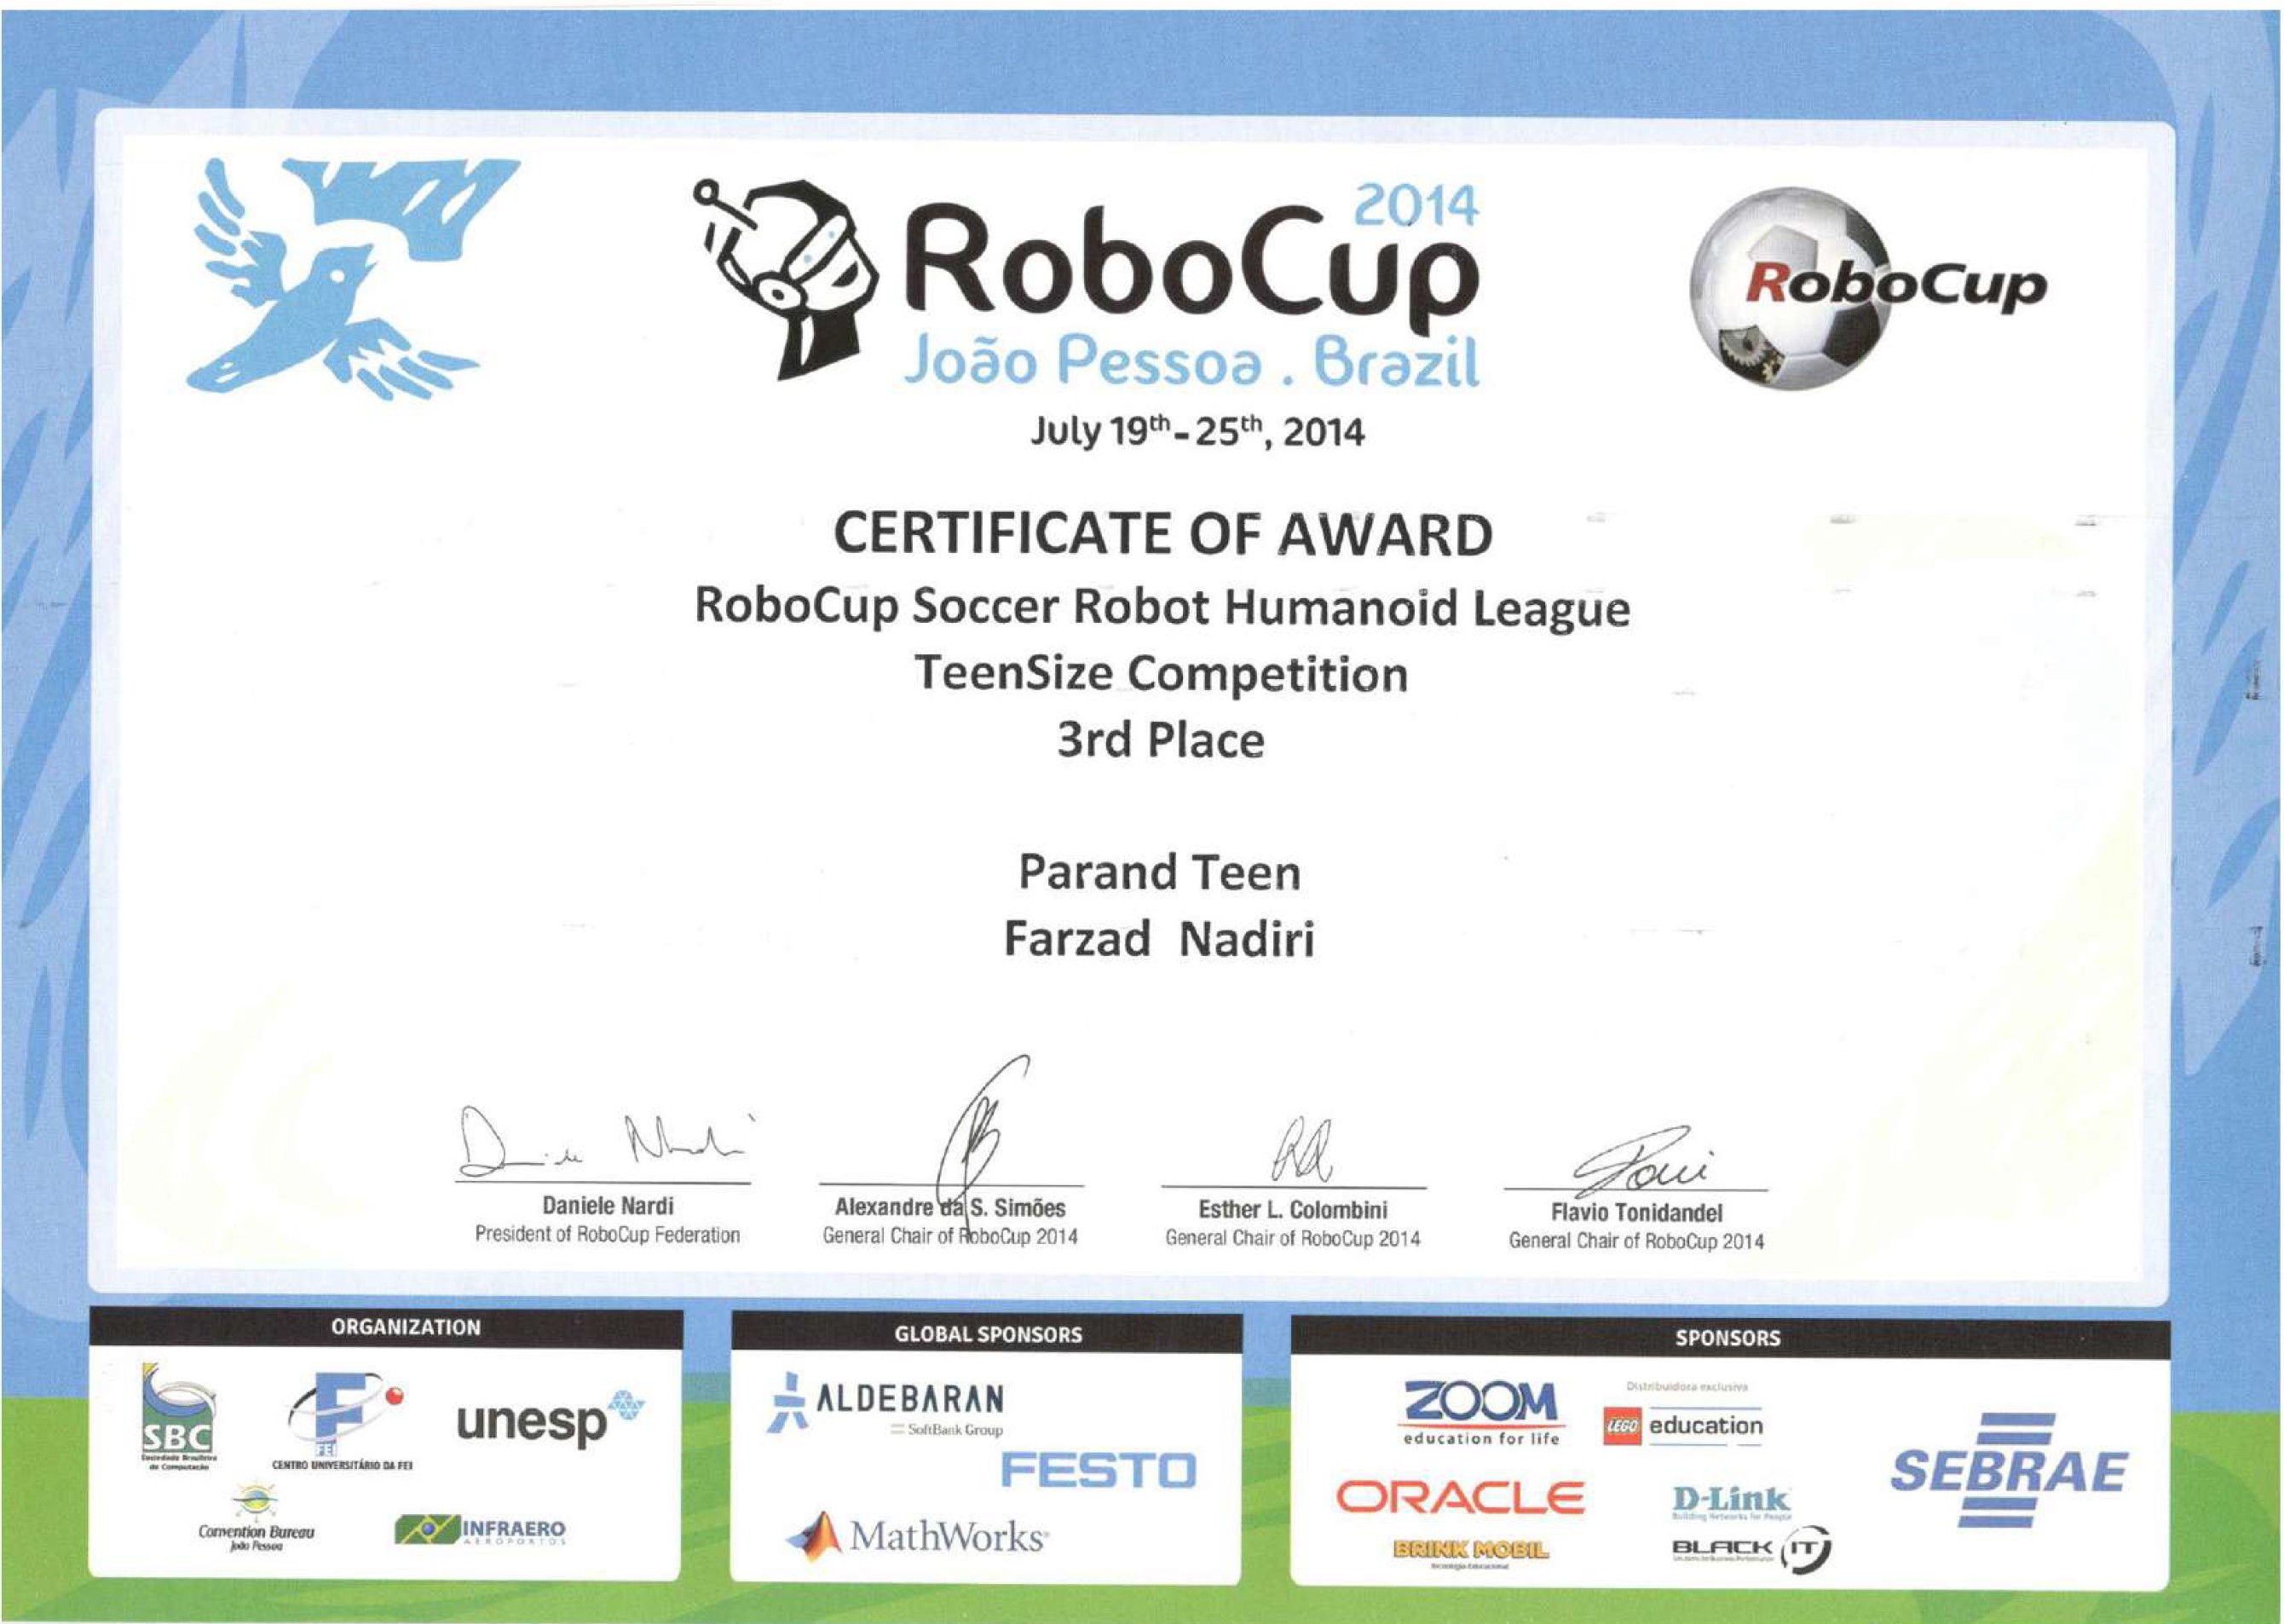
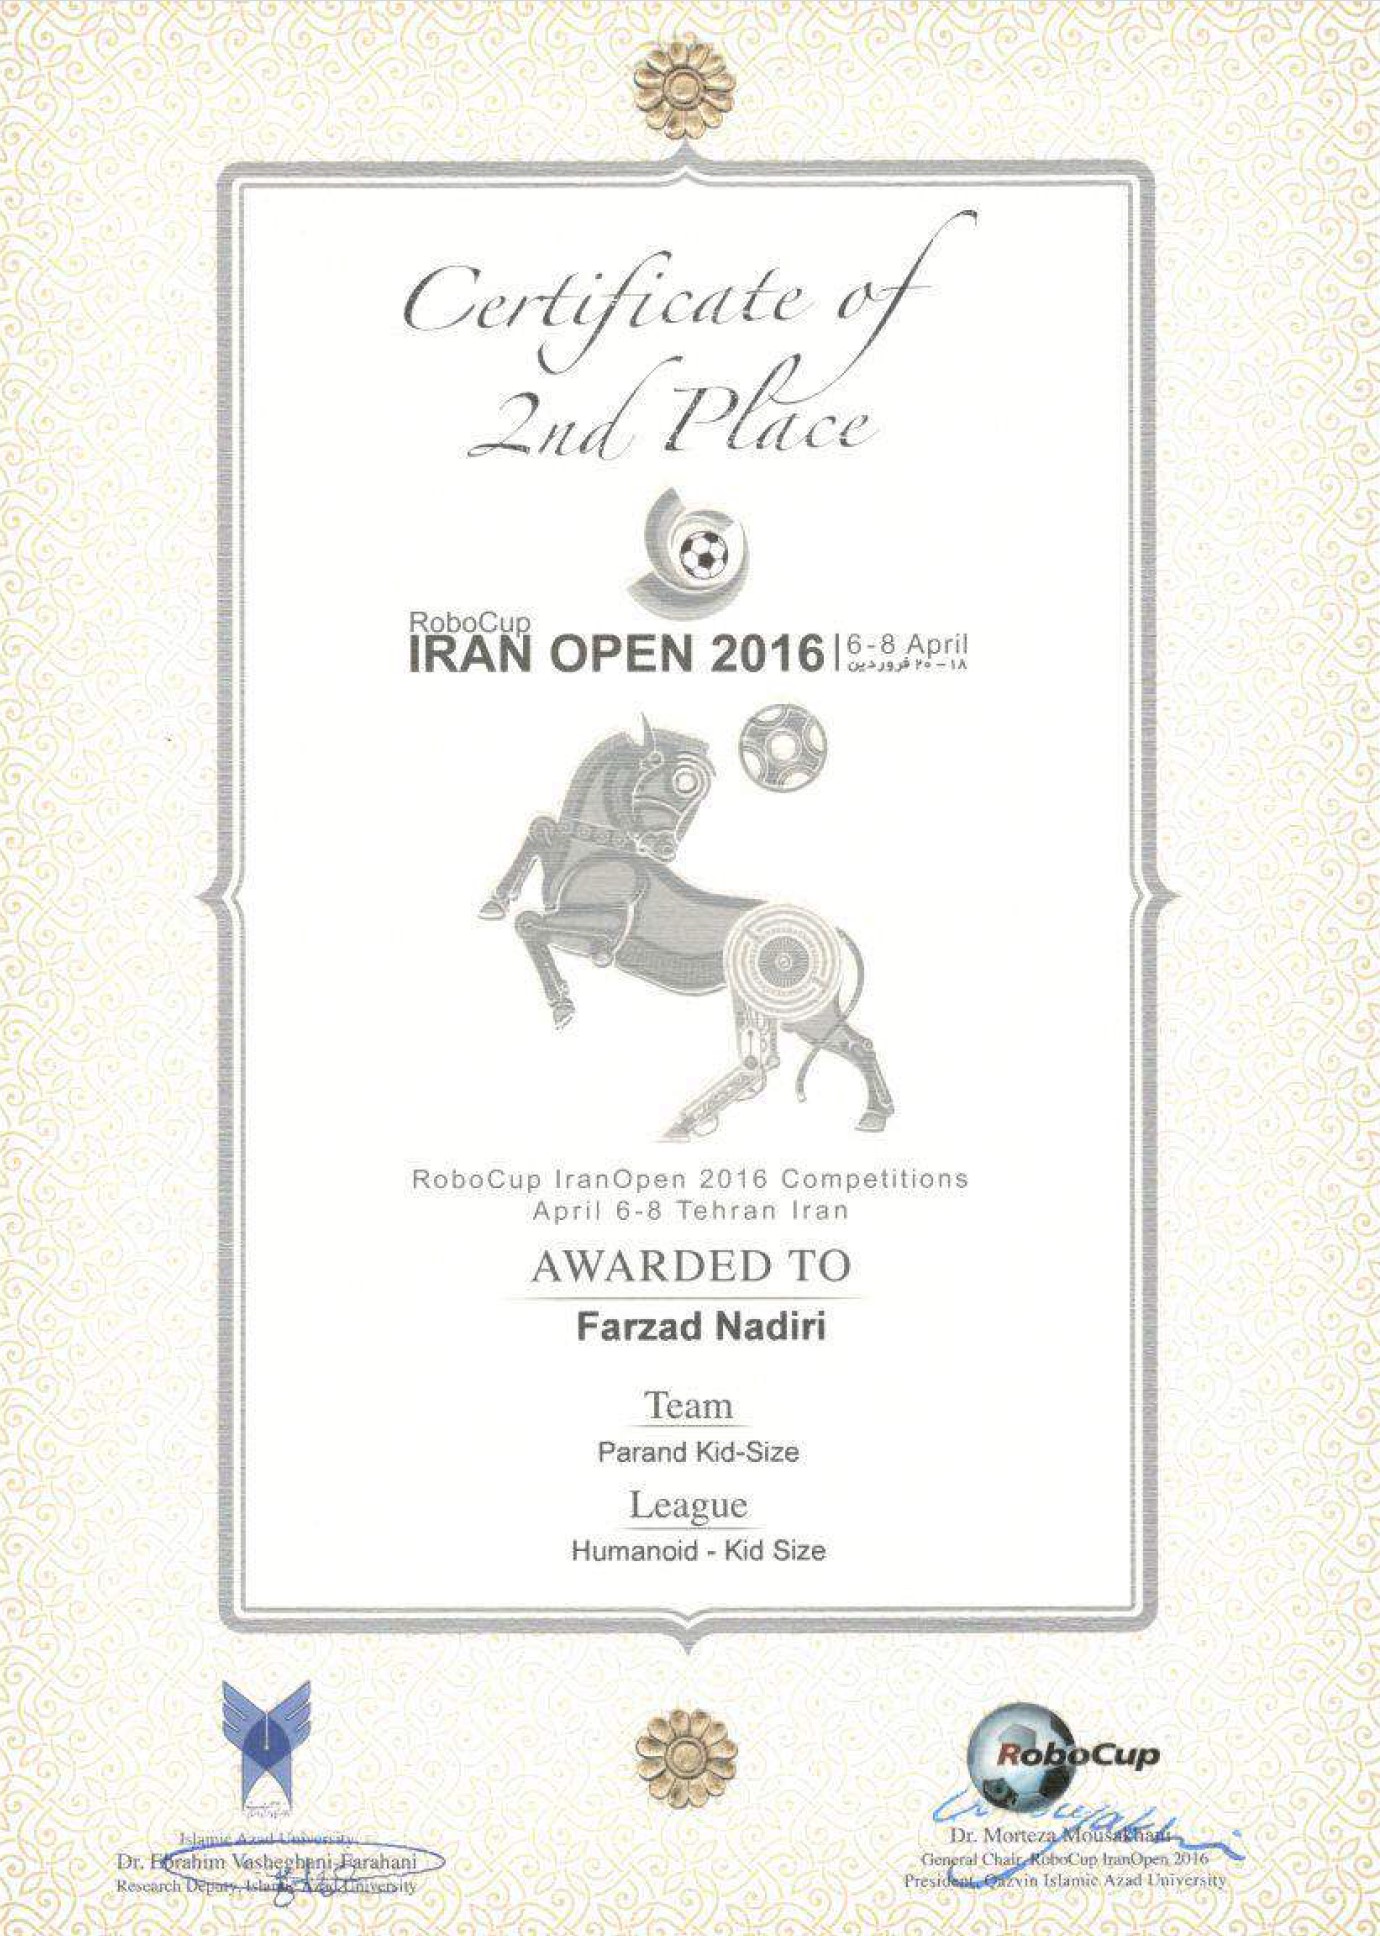
- RoboCup, Kid Size Humanoid
Journal reviewing
- Nature, Scientific Reports, Aug 2025 to Present, Vancouver, Canada, link
- Springer, Computational Intelligence Systems, Sep 2025 to Present, Vancouver, Canada, link
- Springer, Cognitive Computation, Feb 2025 to Present, Vancouver, Canada, link
- Springer, Supercomputing, Feb 2025 to Present, Vancouver, Canada, link
- Springer, Discover Applied Sciences, Feb 2025 to Present, Vancouver, Canada, link
- Springer, Discover Artificial Intelligence, Feb 2025 to Present, Vancouver, Canada, link
- International Journal of Humanoid Robotics, Aug 2025 to Jan 2026, Vancouver, Canada, link
- COJ Robotics and Artificial Intelligence, COJRA, Jul 2025 to Jan 2026, Vancouver, Canada, link
Certifications and training
- Machine Learning Specialization, Stanford Online and DeepLearning.AI, Coursera, link
- Deep Learning Specialization, DeepLearning.AI, Coursera, Neural Networks and Deep Learning, Improving Deep Neural Networks, Structuring Machine Learning Projects, Convolutional Neural Networks
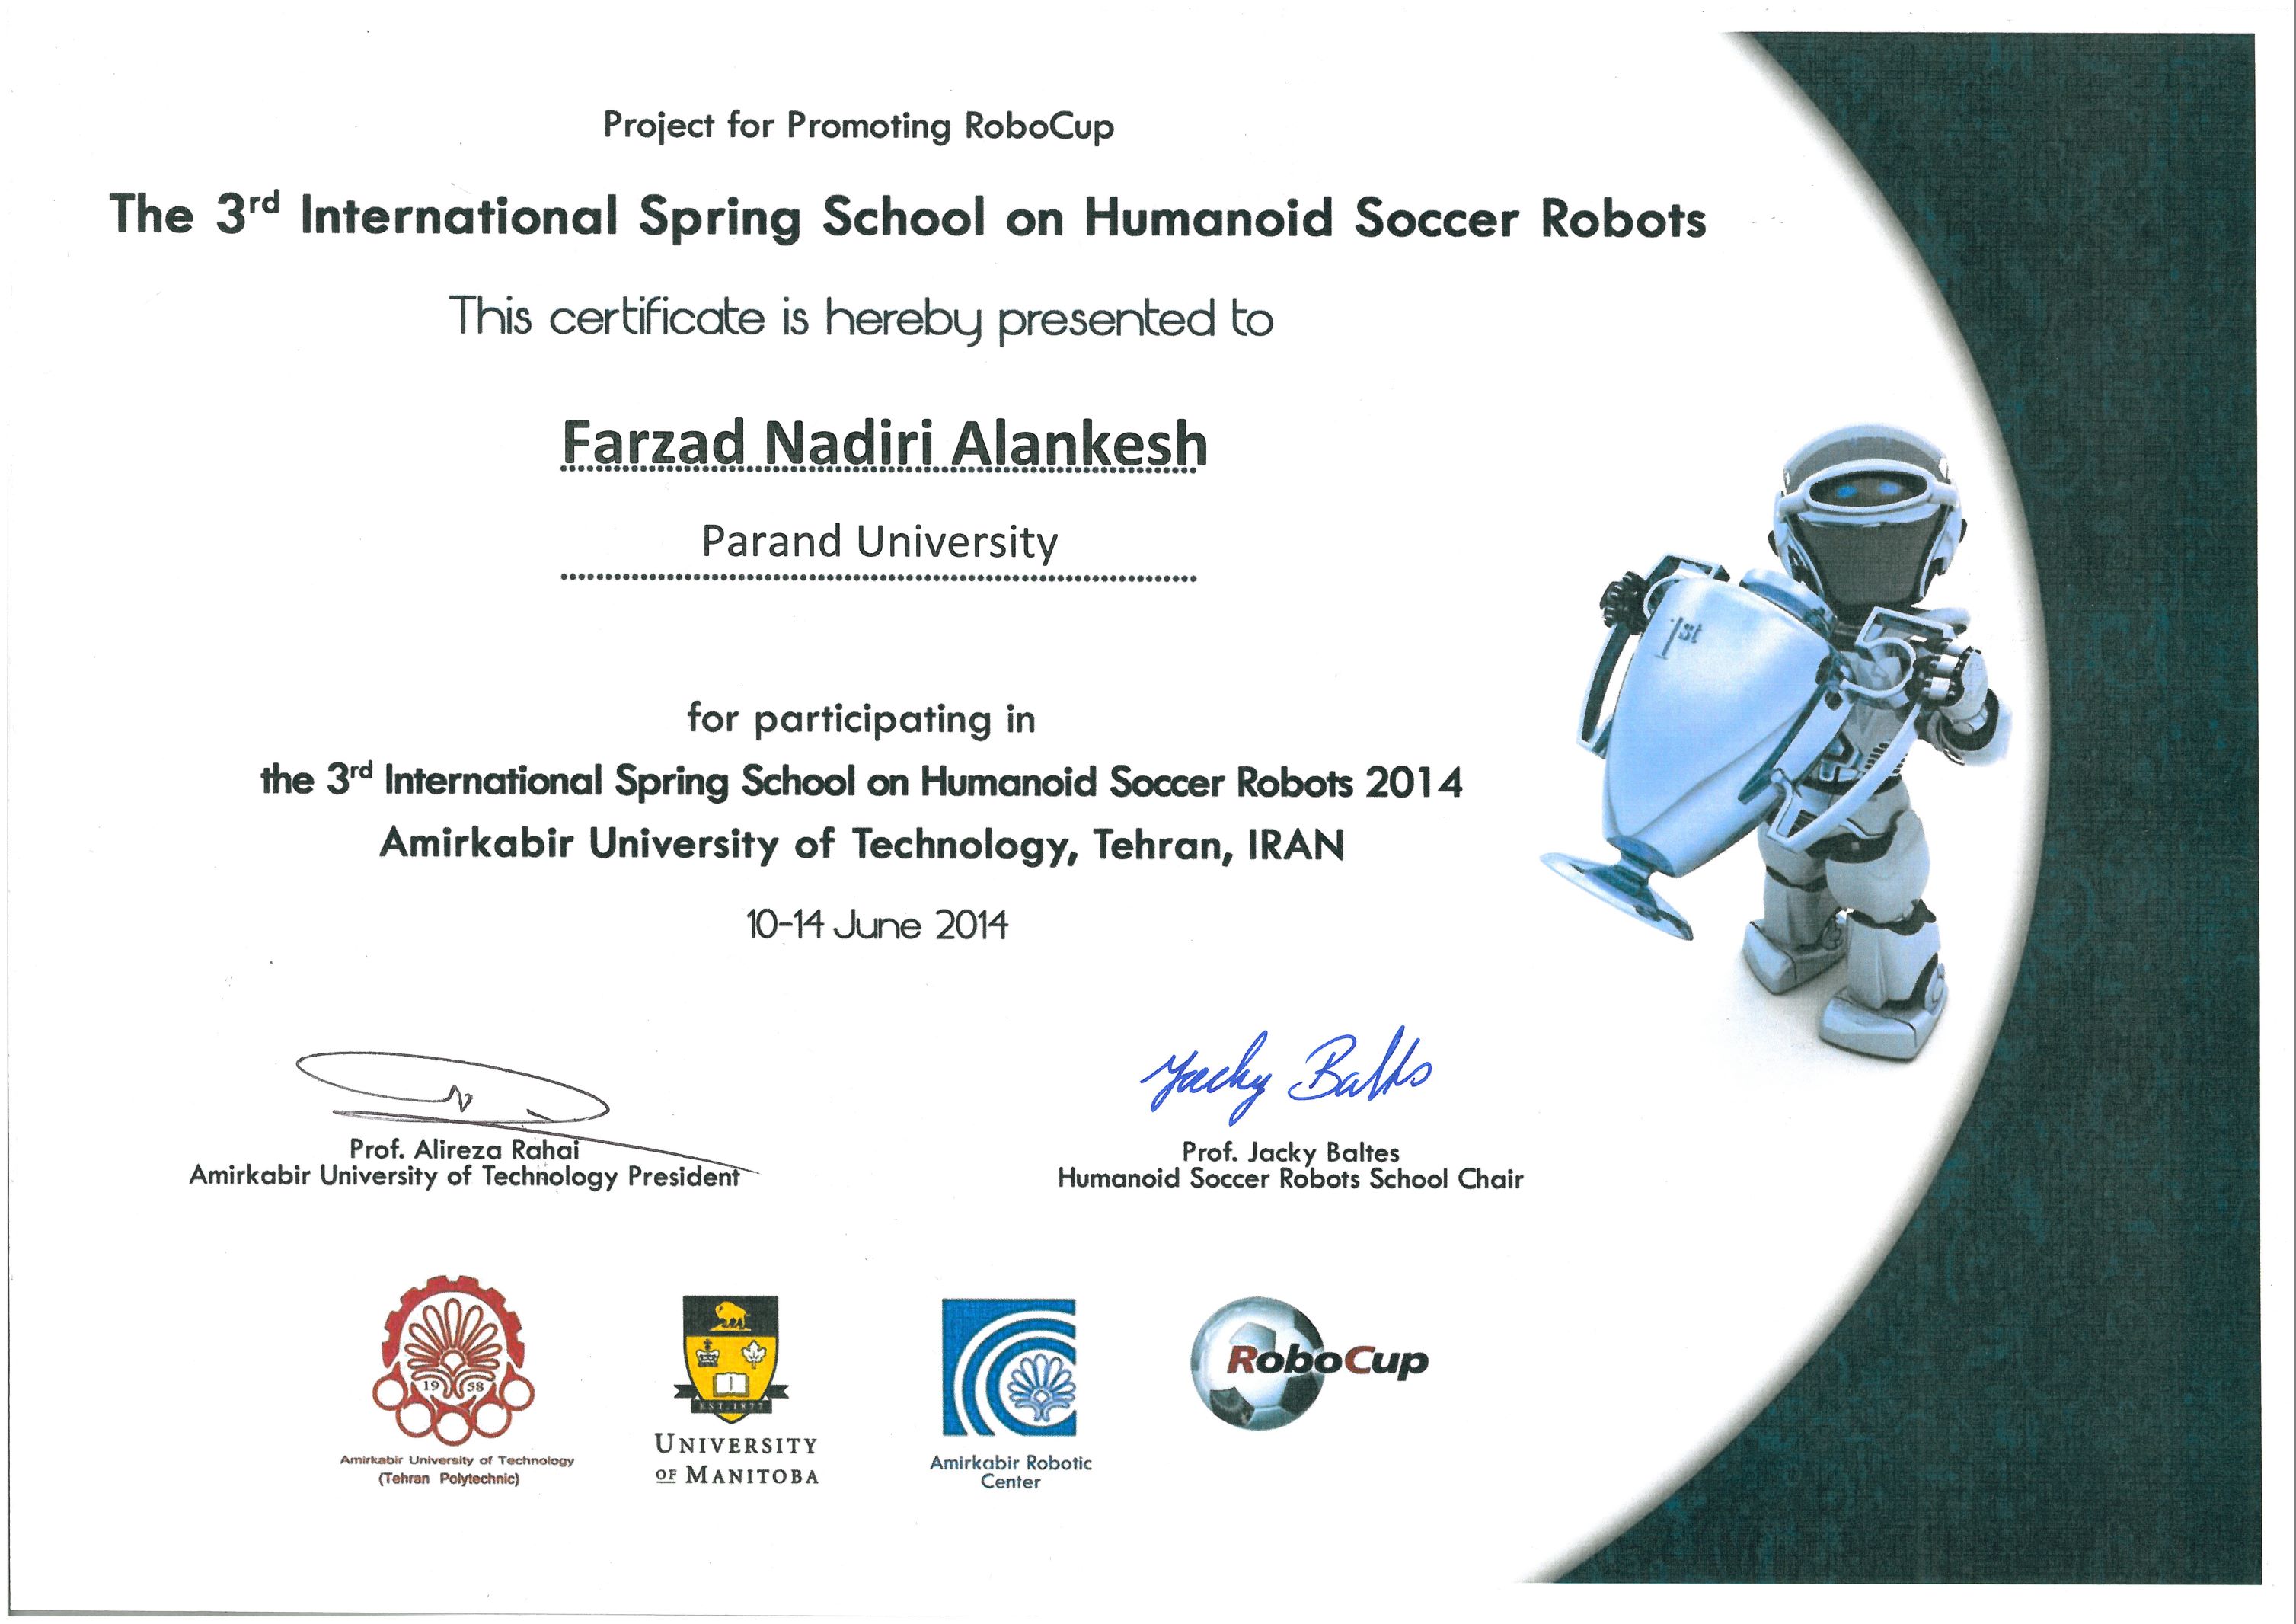
- International Spring School on Humanoid Soccer Robots, link
Volunteering
- Teaching Assistant, Azad University, Apr 2011 to Jun 2012, Tehran, Iran